Research
My research focuses on Vehicle Stability Analysis, Motion Control (particularly the coordination between stability control and trajectory tracking), Trajectory Planning, and Real-Vehicle Platform Development, especially under extreme driving conditions, including high speeds, low-adhesion roads, and highly nonlinear vehicle dynamics. Select a topic below for a more detailed introduction.
Vehicle Lateral Stability Analysis
Real-time characterization and estimation of nonlinear vehicle stability boundaries to guide vehicle motion control.
Explore this research →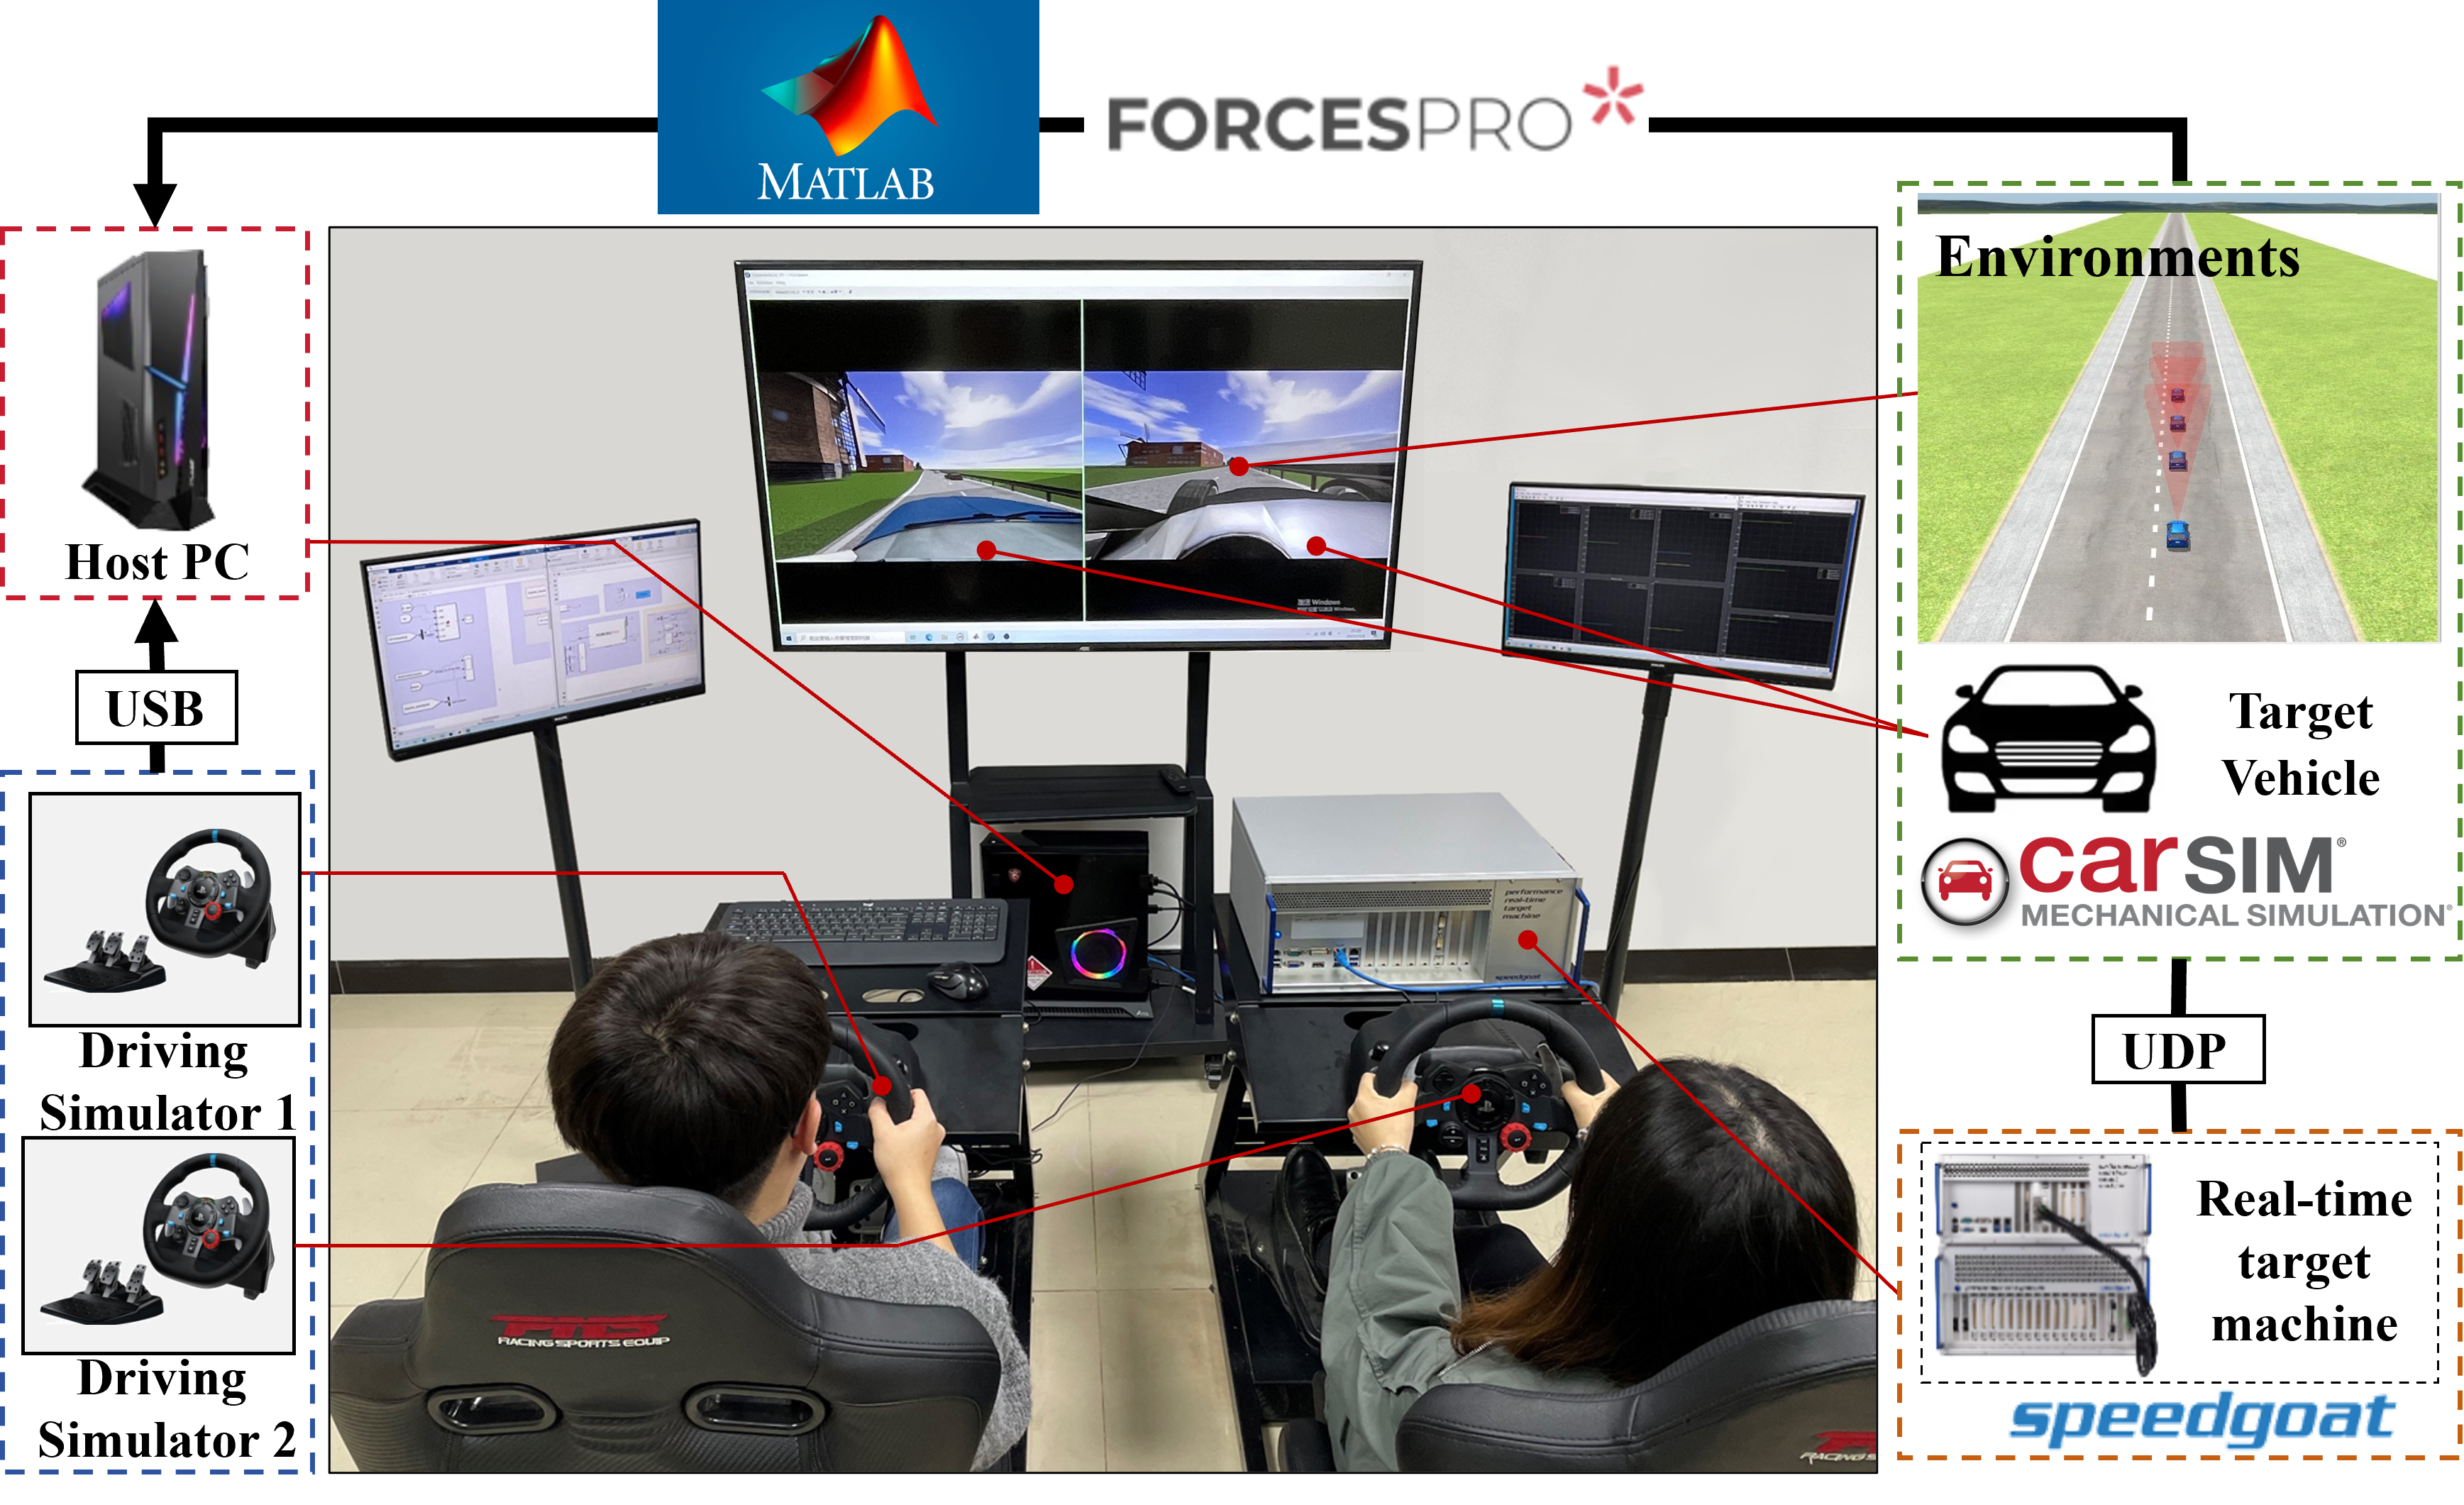
Coordinated Tracking and Stability Control
Longitudinal–lateral coupled trajectory tracking and stability control for distributed-drive electric vehicles operating near their handling limits.
Explore this research →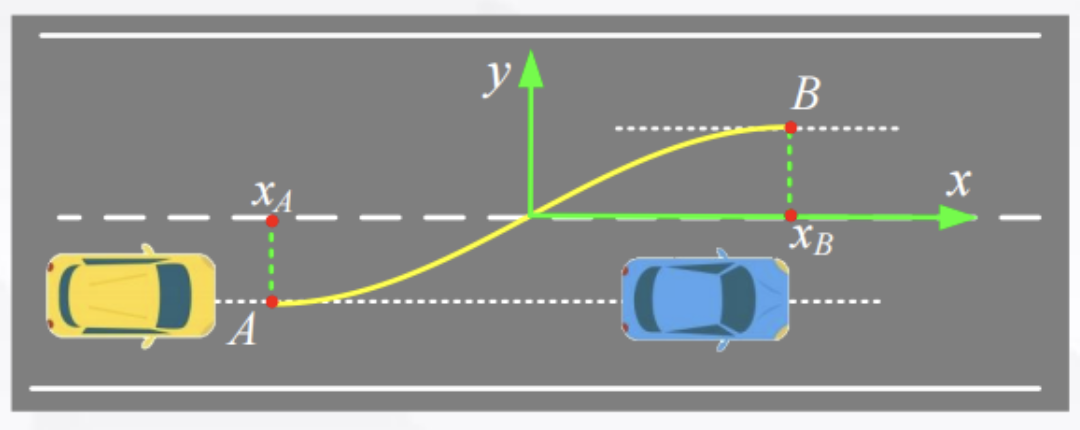
Model–Data-Driven Trajectory Planning
Integrating vehicle dynamics models and deep reinforcement learning for trajectory planning in interactive and extreme autonomous-driving scenarios.
Explore this research →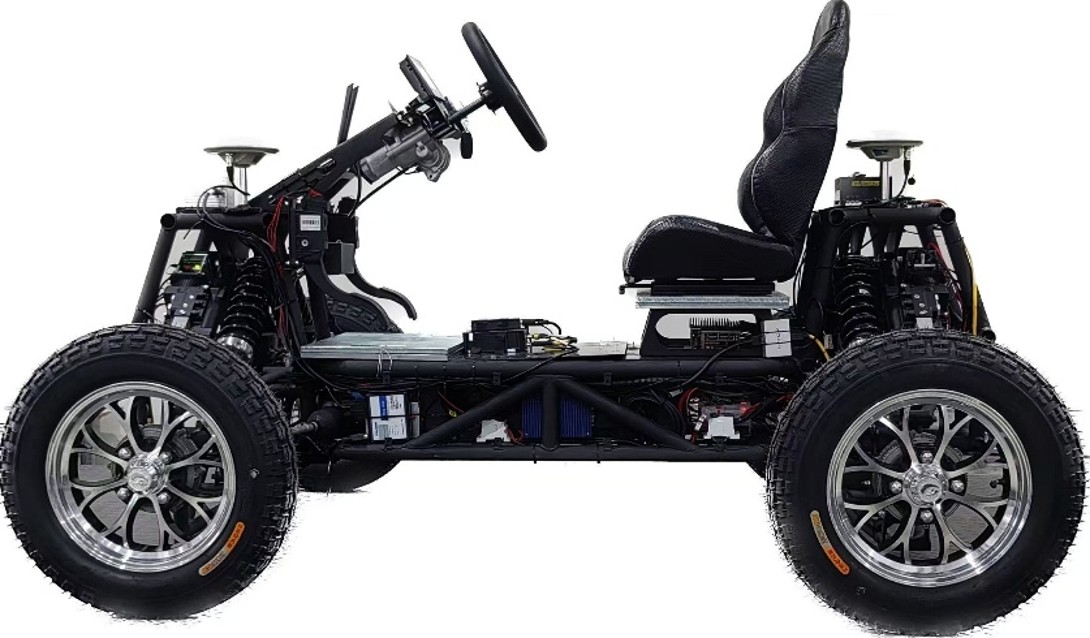
Real-Vehicle Platform
Development of a distributed-drive electric vehicle platform featuring four-wheel-independent drive, steer-by-wire, and active suspension systems for experimental validation.
Explore this research →