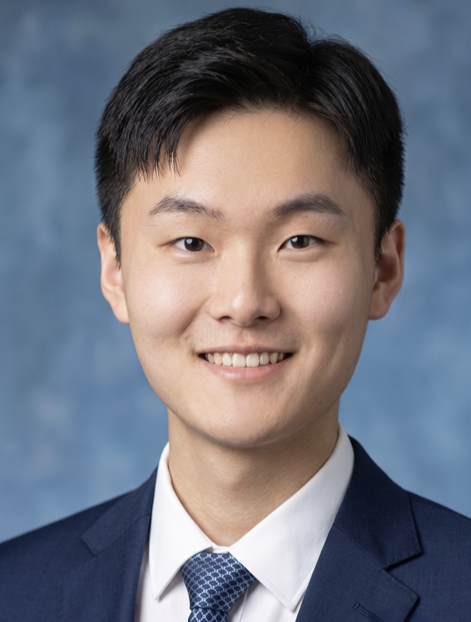
 About Me
Hello! My name is Chengye Wang, and i am a master student at the School of Mechanical Engneering of Beijing Institute of Technology under the supervision of Prof.Yechen Qin.
I got my Bachelor’s degree at the College of Automotive Engneering of Jilin University under the supervison of Prof.Nan Xu in 2024.
My research interests focus on trajectory planning and motion control of autonomous vehicles especially under extreme scenarios. Based on traditional vehicle dynamic method, i am now thrilled to try to apply the advanced technology such as machine learning into improving the motion performance under complex envrionments.
I am very motivated and passionate about combing the vehicle dynamic with advanced technology. I am now open to PhD positions especially in leaning-based control and planning of autonomous vehicles. Please feel free to reach out! Here is me Reasearch Portfolio
 News
[2026.5] Our two articles “A Risk-Aware Decision Making and Motion Planning Framework for Interactive Autonomous Driving” and “Coordinated Tracking and Stability Control of Automated Vehicles at the Limits: A Controlled Stability Region Approach” have been accepted by IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), Naples, Italy. It will be my first trip to Europe and look forward to making good connections!
[2026.3] Warm welcome to the Prof.Amir Khajepour’s group at University of Waterloo, Canada! I am honored to present my recent research on “Coordinated Tracking and Stability Control of Automated Vehicles at the Limits: A Controlled Stability Region Approach” on behalf of our Lab. I am looking forward to the future collaboration with Prof.Amir Khajepour and his team.
[2026.1] Our article “MCTP: A Multi-Coupled Dynamics Trajectory Planning Scheme for Autonomous Driving in Extreme Conditions” has been accepted by IEEE Transactions on Automation Science and Engineering(IF=6.4, Q2, TOP)!The article presents a method for trajectory planning which considered the multi-coupled vehicle dynamics including lateral-longitudinal motion coupling, tire force coupling, and lateral instability. I provided the path tracking method and assistance in real-vehicle test for the artcile.
[2025.9] Our article “Real-time multidimensional vehicle dynamic stability domain calculation and its application in intelligent vehicles” has been accepted by Intelligent and Connected Vehicles Symposium(ICVS) 2025, SAE International. The article presents a stable region estimation method based on neural network mapping, and applies it to the stability controller.
[2025.8] Our article “基于动态稳定边界的智能车辆路径跟踪控制方法”(Dynamic Region of Stability Integrated Path-tracking Control for Intelligent Vehicles)has been accepted by 机械工程学报(Chinese Journal of Mechanical Engineering)!I provide a stable domain estimation method based on Lyapunov function(LF) for the path-tracking controller.
[2025.7] Our team designed a Four-wheel independent drive electric vehicle. I designed the architecture of steering, driving and braking modules which can be controlled either via a remote control or manually. Despite weighing only 300kg, we achieved a speed of over 50 km/h and the ability to climb a steep slope of 30°!Here is part vedio.
[2025.5] Our group won the 4th prize in City and High-Speed Road, Onsite Autonomous Driving Algorithm Challenge 2025, the part vedio can be seen in here.
[2024.12] I completed the dual-vehicle state communication based on Ubuntu/ROS, and this algorithm was used in path planning-related research and we provide a interesting video based on BYD,Shenzheng,China test platfrom.
[2024.9] I was recommended for admission to Beijing Institute of Technology for graduate studies with the top 5% academic performance at Jilin University.
 Publications
Journal Papers(Provide orginal text whenever possible)
张钰, 王成烨, 杜甫, 董明明, 秦也辰 and 毛明. “Dynamic Region of Stability Integrated Path-tracking Control for Intelligent Vehicles”, Chinese Journal of Mechanical Engineering. (Accepted)
Hu, XuePeng; Zhang, Yu; Wang, Chengye; Wang, Zhenfeng; Qin, Yechen“MCTP: A Multi-Coupled Dynamics Trajectory Planning Scheme for Autonomous Driving in Extreme Conditions”, IEEE Transactions on Automation Science and Engineering. (Accepted, IF=6.4, Q2, TOP)
He, Jingqi; Yang, Ziyi; Shi, Shaoyang; Wang, Chengye; Zhang Yu; Qin, Yechen “Tire Model-Free Tire-Road Friction Coefficient Estimation for Unmanned Platforms via Vision-Dynamics Dual-Confidence Fusion”], Mechanical Systems and Signal Processing. (Under review, IF=10.2, Q1, TOP)
Chengye Wang, Shaoyang Shi, Yu Zhang, and Yechen Qin, “Controlled Stability Region-Guided Lateral-Longitudinal Trajectory Tracking for Autonomous Vehicles”, IEEE Transactions on Industrial Electronics. (Under review, IF=7.4, Q1, TOP)
Shaoyang Shi, Kai Yang, Chengye Wang, Dongwei Li, Yu Zhang and Yechen Qin, “Self-Evolving Reinforcement Learning Framework for Autonomous Driving via Uncertainty-Aware Collision-Risk Supervision”, IEEE Transactions on Automation Science and Engineering. (Under review, IF=7.9, Q2, TOP)
Conference Proceedings
Shaoyang Shi, Yu Zhang, Kai Yang, Chengye Wang, Zhenfeng Wang, Yechen Qin. “A Risk-Aware Decision Making and Motion Planning Framework for Interactive Autonomous Driving”, 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), Naples, Italy.IEEE. (Accepted)
Chengye Wang, Yu Zhang, Xuepeng Hu, Shaoyang Shi, Jingqi He, Yechen Qin. “Coordinated Tracking and Stability Control of Automated Vehicles at the Limits: A Controlled Stability Region Approach”, 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), Naples, Italy.IEEE. (Accepted)
Chengye Wang, Yu Zhang, Xuepeng Hu, Haipeng Qin, Guoli Wang, Yechen Qin. “Real-time multidimensional vehicle dynamic stability domain calculation and its application in intelligent vehicles”, Intelligent and Connected Vehicles Symposium(ICVS) 2025, Chongqing, China.SAE International. (Accepted)
 Educations
[2024.09-2027.06], Graduate, School of Mechanical Engneering, Beijing Institute of Technology, Beijing, China.
[2020.09-2024.06], Undergraduate, College of Automotive Engneering, Jilin University, Changchun, China. GPA:3.75/4.0
 Talks
[2026.03] Coordinated Tracking and Stability Control of Automated Vehicles at the Limits: A Controlled Stability Region Approach — Research Presentation, Beijing Institute of Technology, Beijing, China
[2025.09] Real-time multidimensional vehicle dynamic stability domain calculation and its application in intelligent vehicles — Talk, ICVS2025, Chongqing, China
 CV
The CV can be downloaded here.
 Team
Currently, our team is actively promoting the research of intelligent chassis under the leadership of Professor Yechen Qin. If you want to be involved in this process or have any questions about my/the team’s research, please visit the team homepage or contact us by email. All emails for academic discussions will be replied within 24 hours.