Coordinated Tracking and Stability Control of Automated Vehicles at the Limits: A Controlled Stability Region Approach
Date:
Abstrcat:Stability criteria serve as the cornerstone of safety for automated vehicles. However, criteria derived from open-loop assumptions often induce conservative interventions, thereby compromising tracking accuracy at handling limits. To address this, this paper presents a Controlled Stability Region (CSR) approach for the coordinated tracking and stability control of automated vehicles. By integrating active control inputs into the nonlinear dynamic system, we quantify a closedloop stability criterion that overcomes the conservatism of open-loop phase plane analysis. Subsequently, a coordinated control strategy (CSR-HMC) is developed, utilizing the CSR as both a dynamic constraint and a weight-adjustment reference to maximize path-tracking potential. Simulations based on a Hardware-in-the-Loop (HiL) platform demonstrate that the CSR-HMC significantly expands the safety boundary compared to open-loop baselines, enabling the vehicle to utilize transient high-maneuverability states and enhance tracking performance in extreme environments.
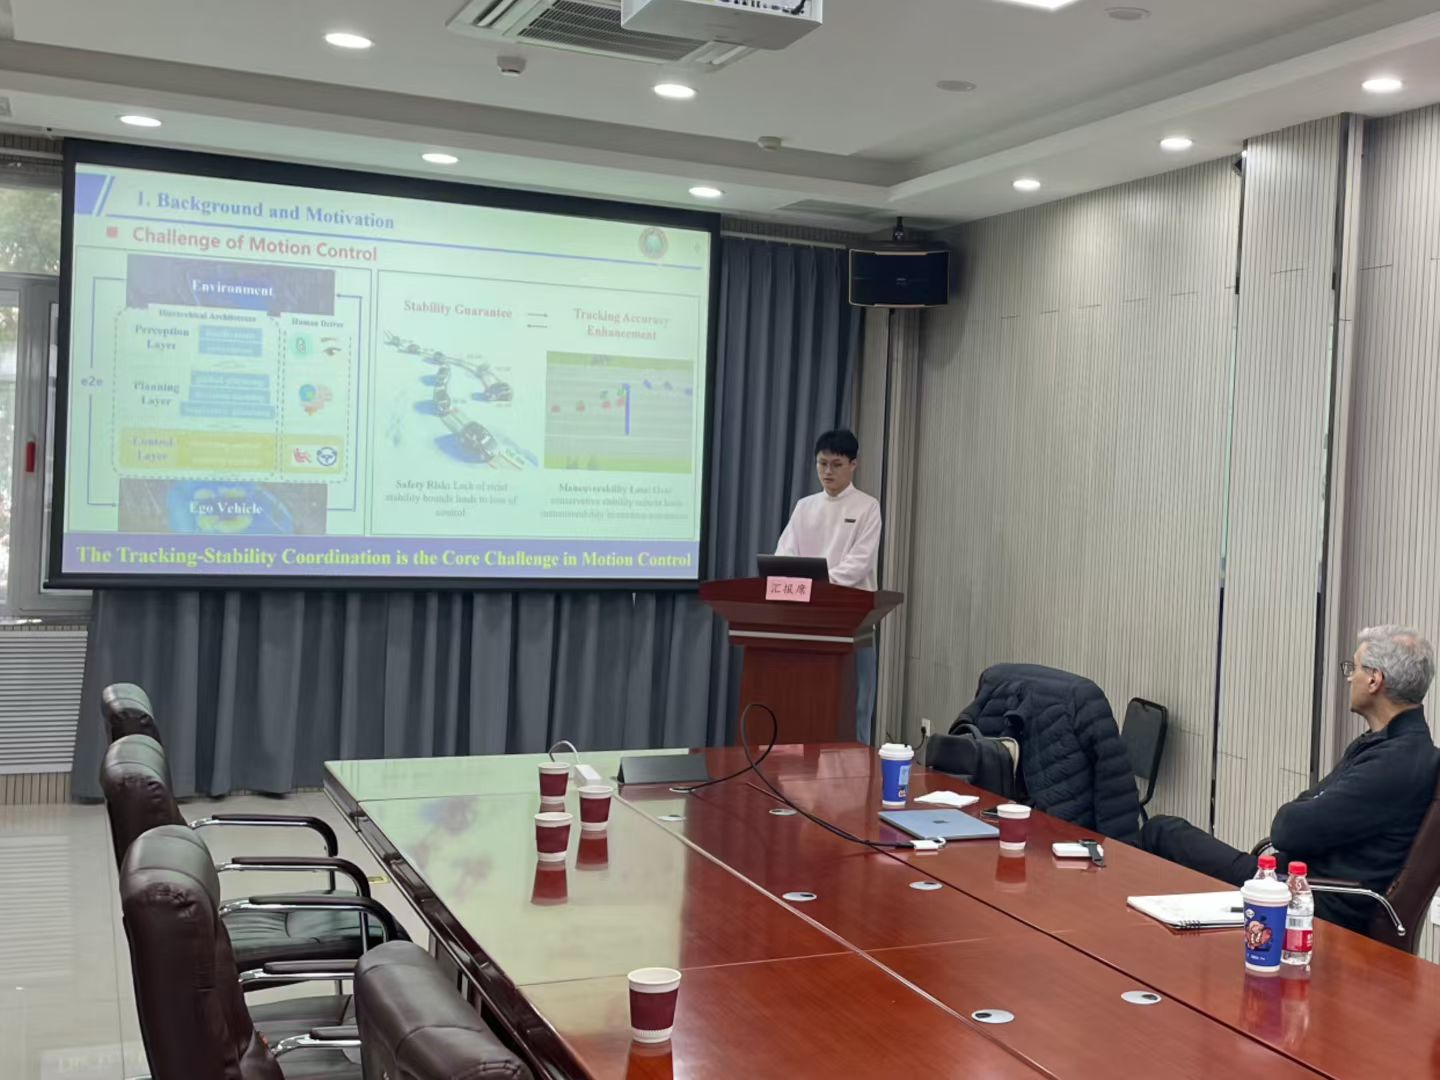
The presentation_pdf here.