Vehicle Lateral Stability Analysis
Research Area 01
Brief
This research investigates how to characterize the nonlinear stability of vehicles in multi-factors. The objective is to provide an interpretable and computationally efficient stability boundary that can be used by planning and control algorithms under changing driving conditions.
Motivation
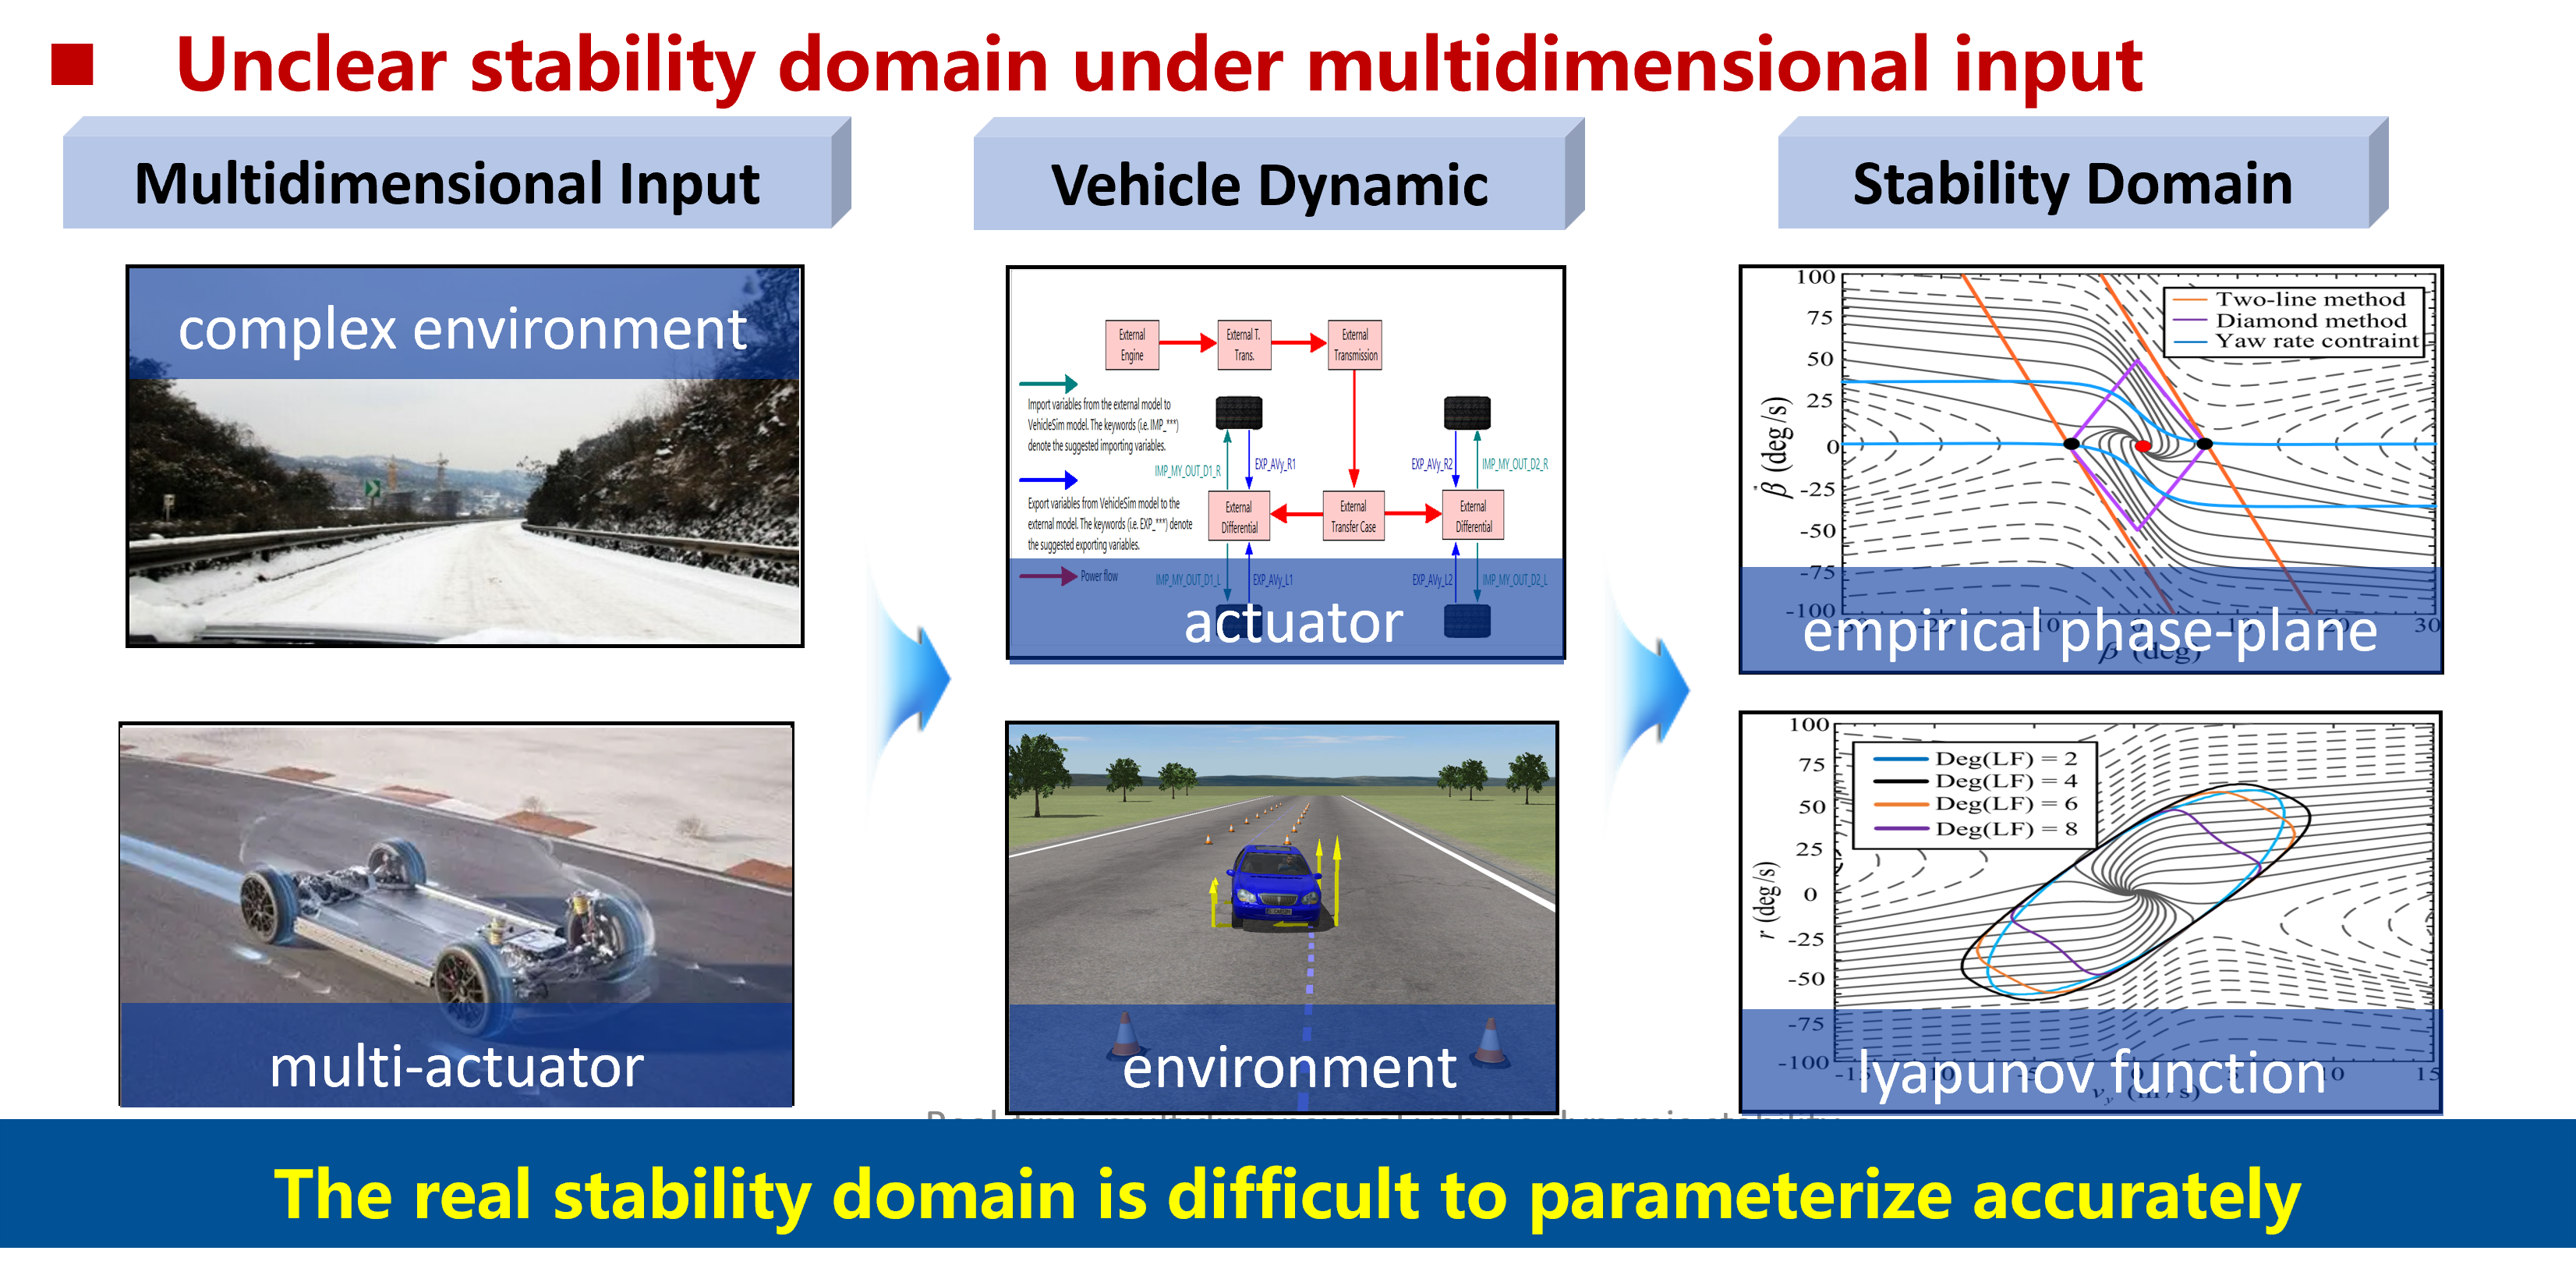
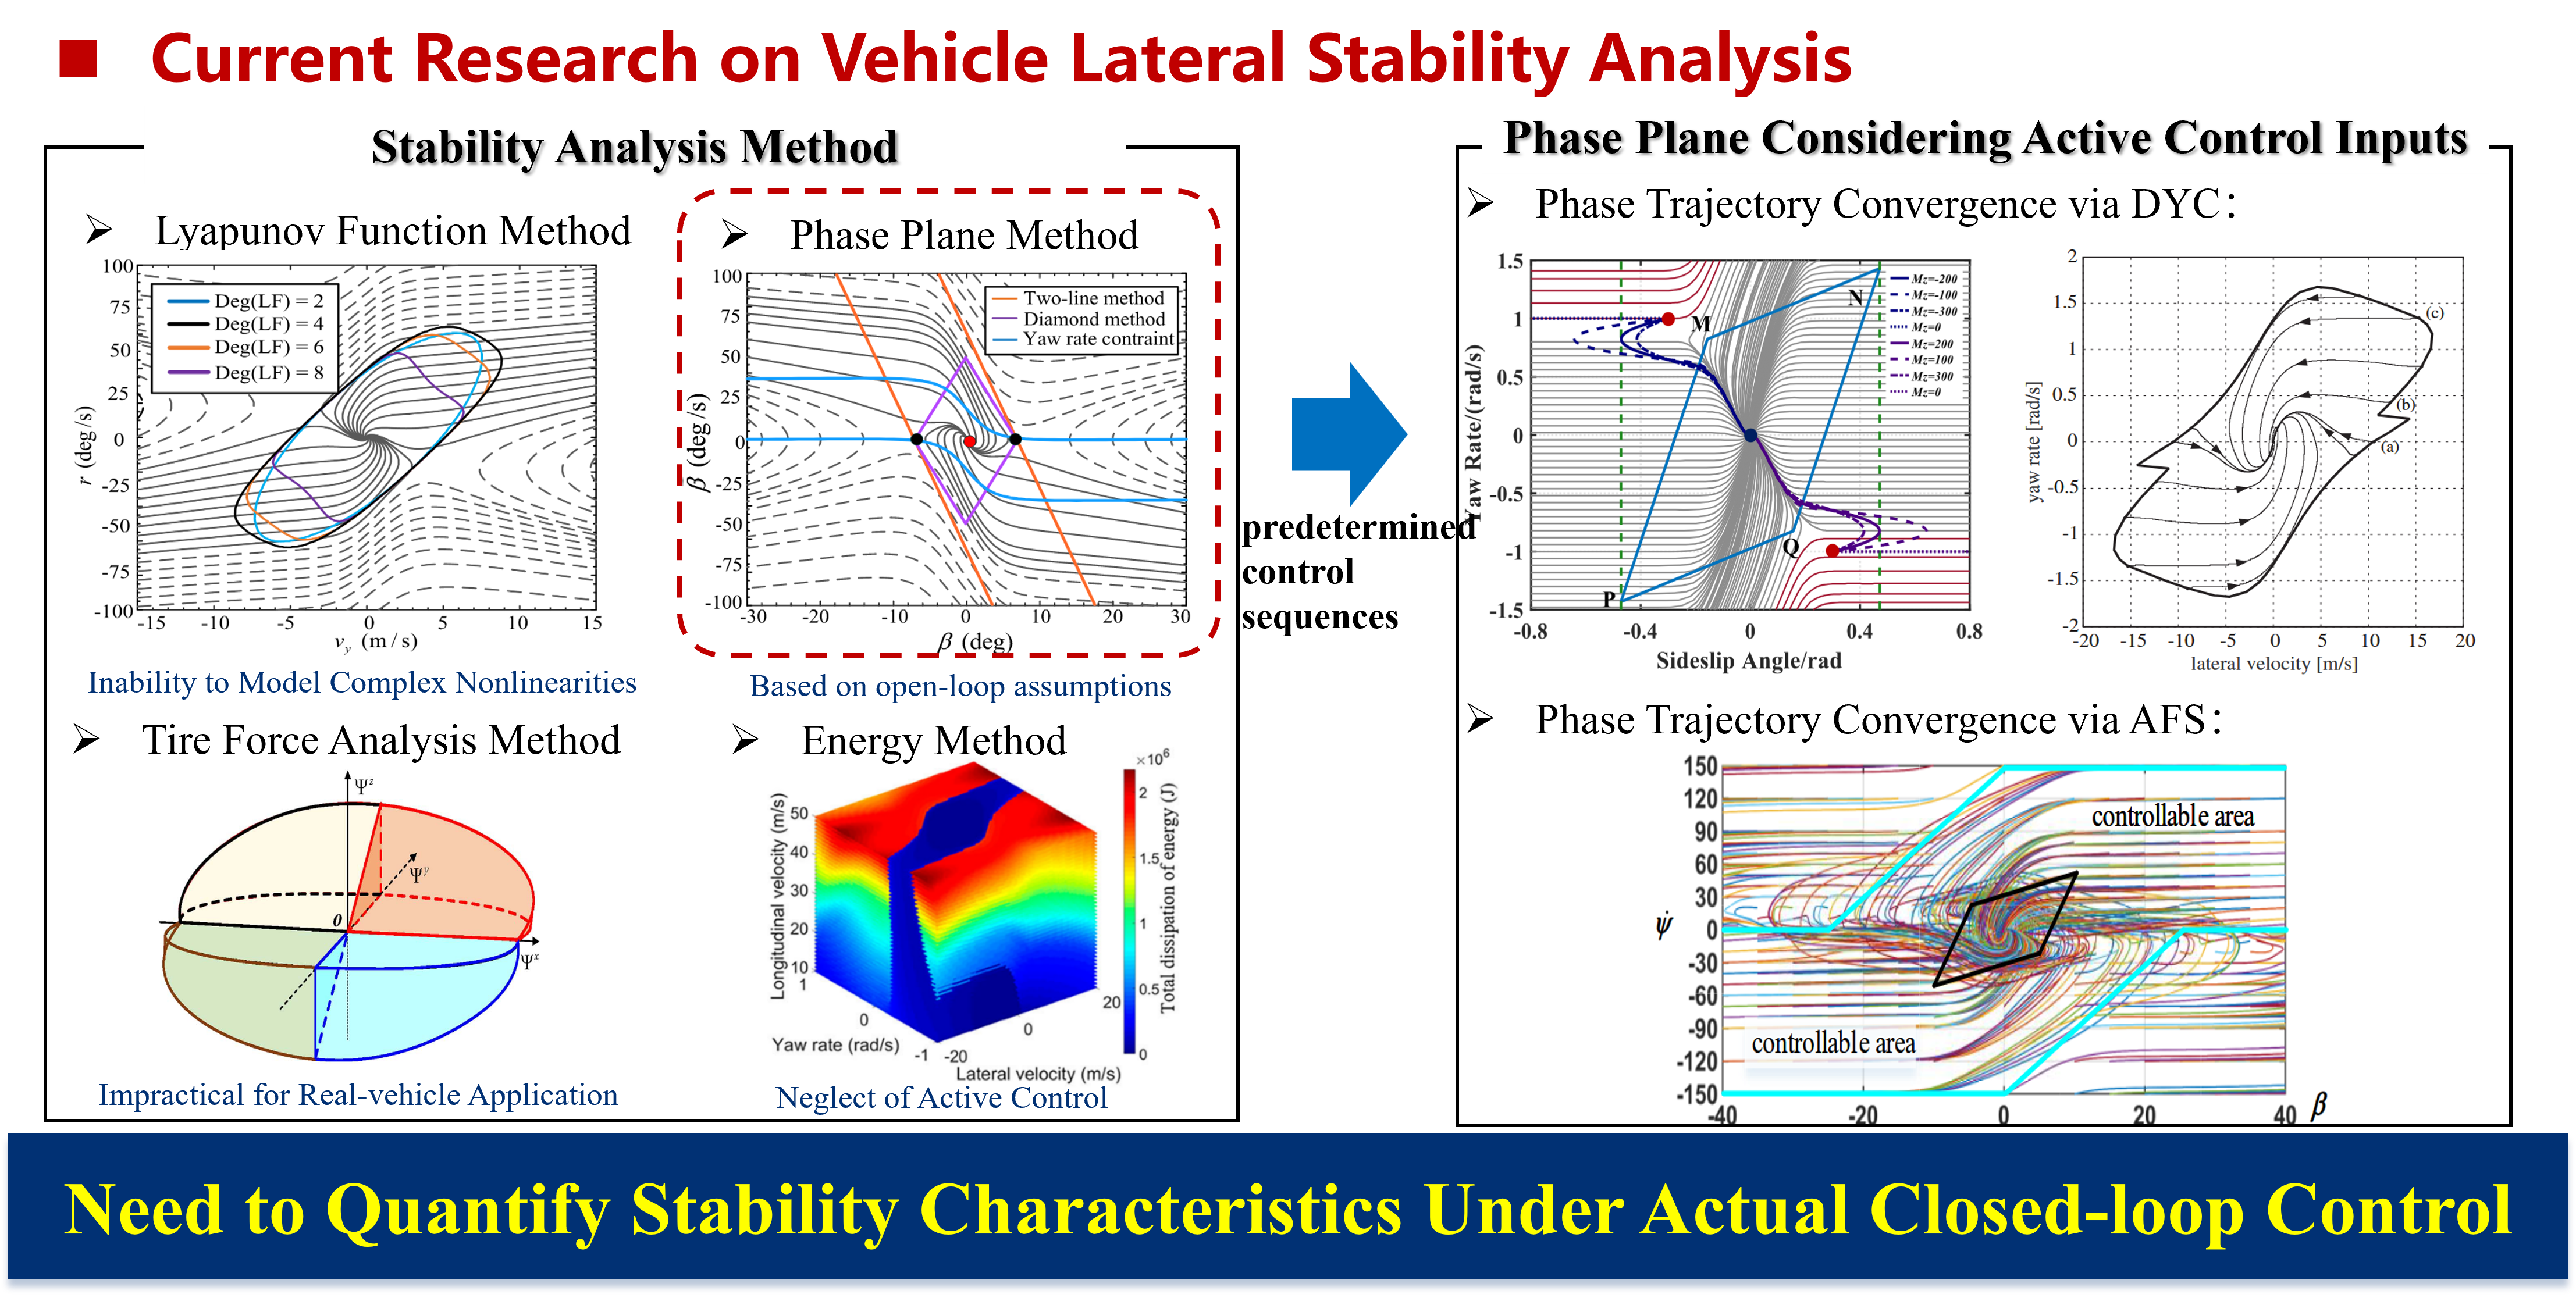
Vehicle stability is fundamental to the safe operation of intelligent vehicles, and the real-time, accurate characterization of the stability domain is crucial for maintaining control across diverse driving conditions. However, the actual stability domain is difficult to parameterize because it is jointly shaped by vehicle dynamics, environmental conditions, time-varying driving inputs, and active control capabilities. Existing methods struggle to capture these multidimensional couplings and often adopt conservative assumptions, thereby underestimating the available stability margin and restricting vehicle performance. For distributed-drive electric vehicles, independent four-wheel torque control and steering coordination can actively extend the controllable stability region. Nevertheless, existing studies rarely investigate closed-loop stability under such multi-actuator control or systematically exploit the resulting controlled stability characteristics. Consequently, trajectory-tracking controllers generally rely on simplified stability constraints, which may cause unnecessary interventions and degrade tracking performance in extreme scenarios such as high-speed cornering and low-adhesion driving.
Approach
- Analyze nonlinear lateral stability in phase-plane by Lyapunov Function Method and Phase Portrait Method.
- Quantify stability boundaries using data-driven mapping and radial- search method.
- Analyze the variation of stability boundary as vehicle states and operating conditions change.
Related publications
- Chengye Wang, Yu Zhang, Xuepeng Hu, Haipeng Qin, Guoli Wang, and Yechen Qin, “Real-time multidimensional vehicle dynamic stability domain calculation and its application in intelligent vehicles,” SAE International, ICVS 2025.
- Yu Zhang, Chengye Wang, Fu Du, Mingming Dong, Yechen Qin, and Ming Mao, “Dynamic Region of Stability Integrated Path-tracking Control for Intelligent Vehicles,” Chinese Journal of Mechanical Engineering.
- Chengye Wang, Yu Zhang, Xuepeng Hu, Shaoyang Shi, Jingqi He, Yechen Qin. “Coordinated Tracking and Stability Control of Automated Vehicles at the Limits: A Controlled Stability Region Approach”, 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), Naples, Italy.IEEE.