Real-Vehicle Platform
Research Area 04
Brief
This research focuses on the development of a distributed-drive electric vehicle experimental platform for validating trajectory-tracking and stability-control algorithms under real-world conditions.
Motivation
Distributed-drive electric vehicles (DDEVs) are considered promising platforms for future autonomous vehicles. Experimental validation is essential for evaluating the practical performance and real-time feasibility of advanced vehicle-control algorithms.
Platform Capabilities
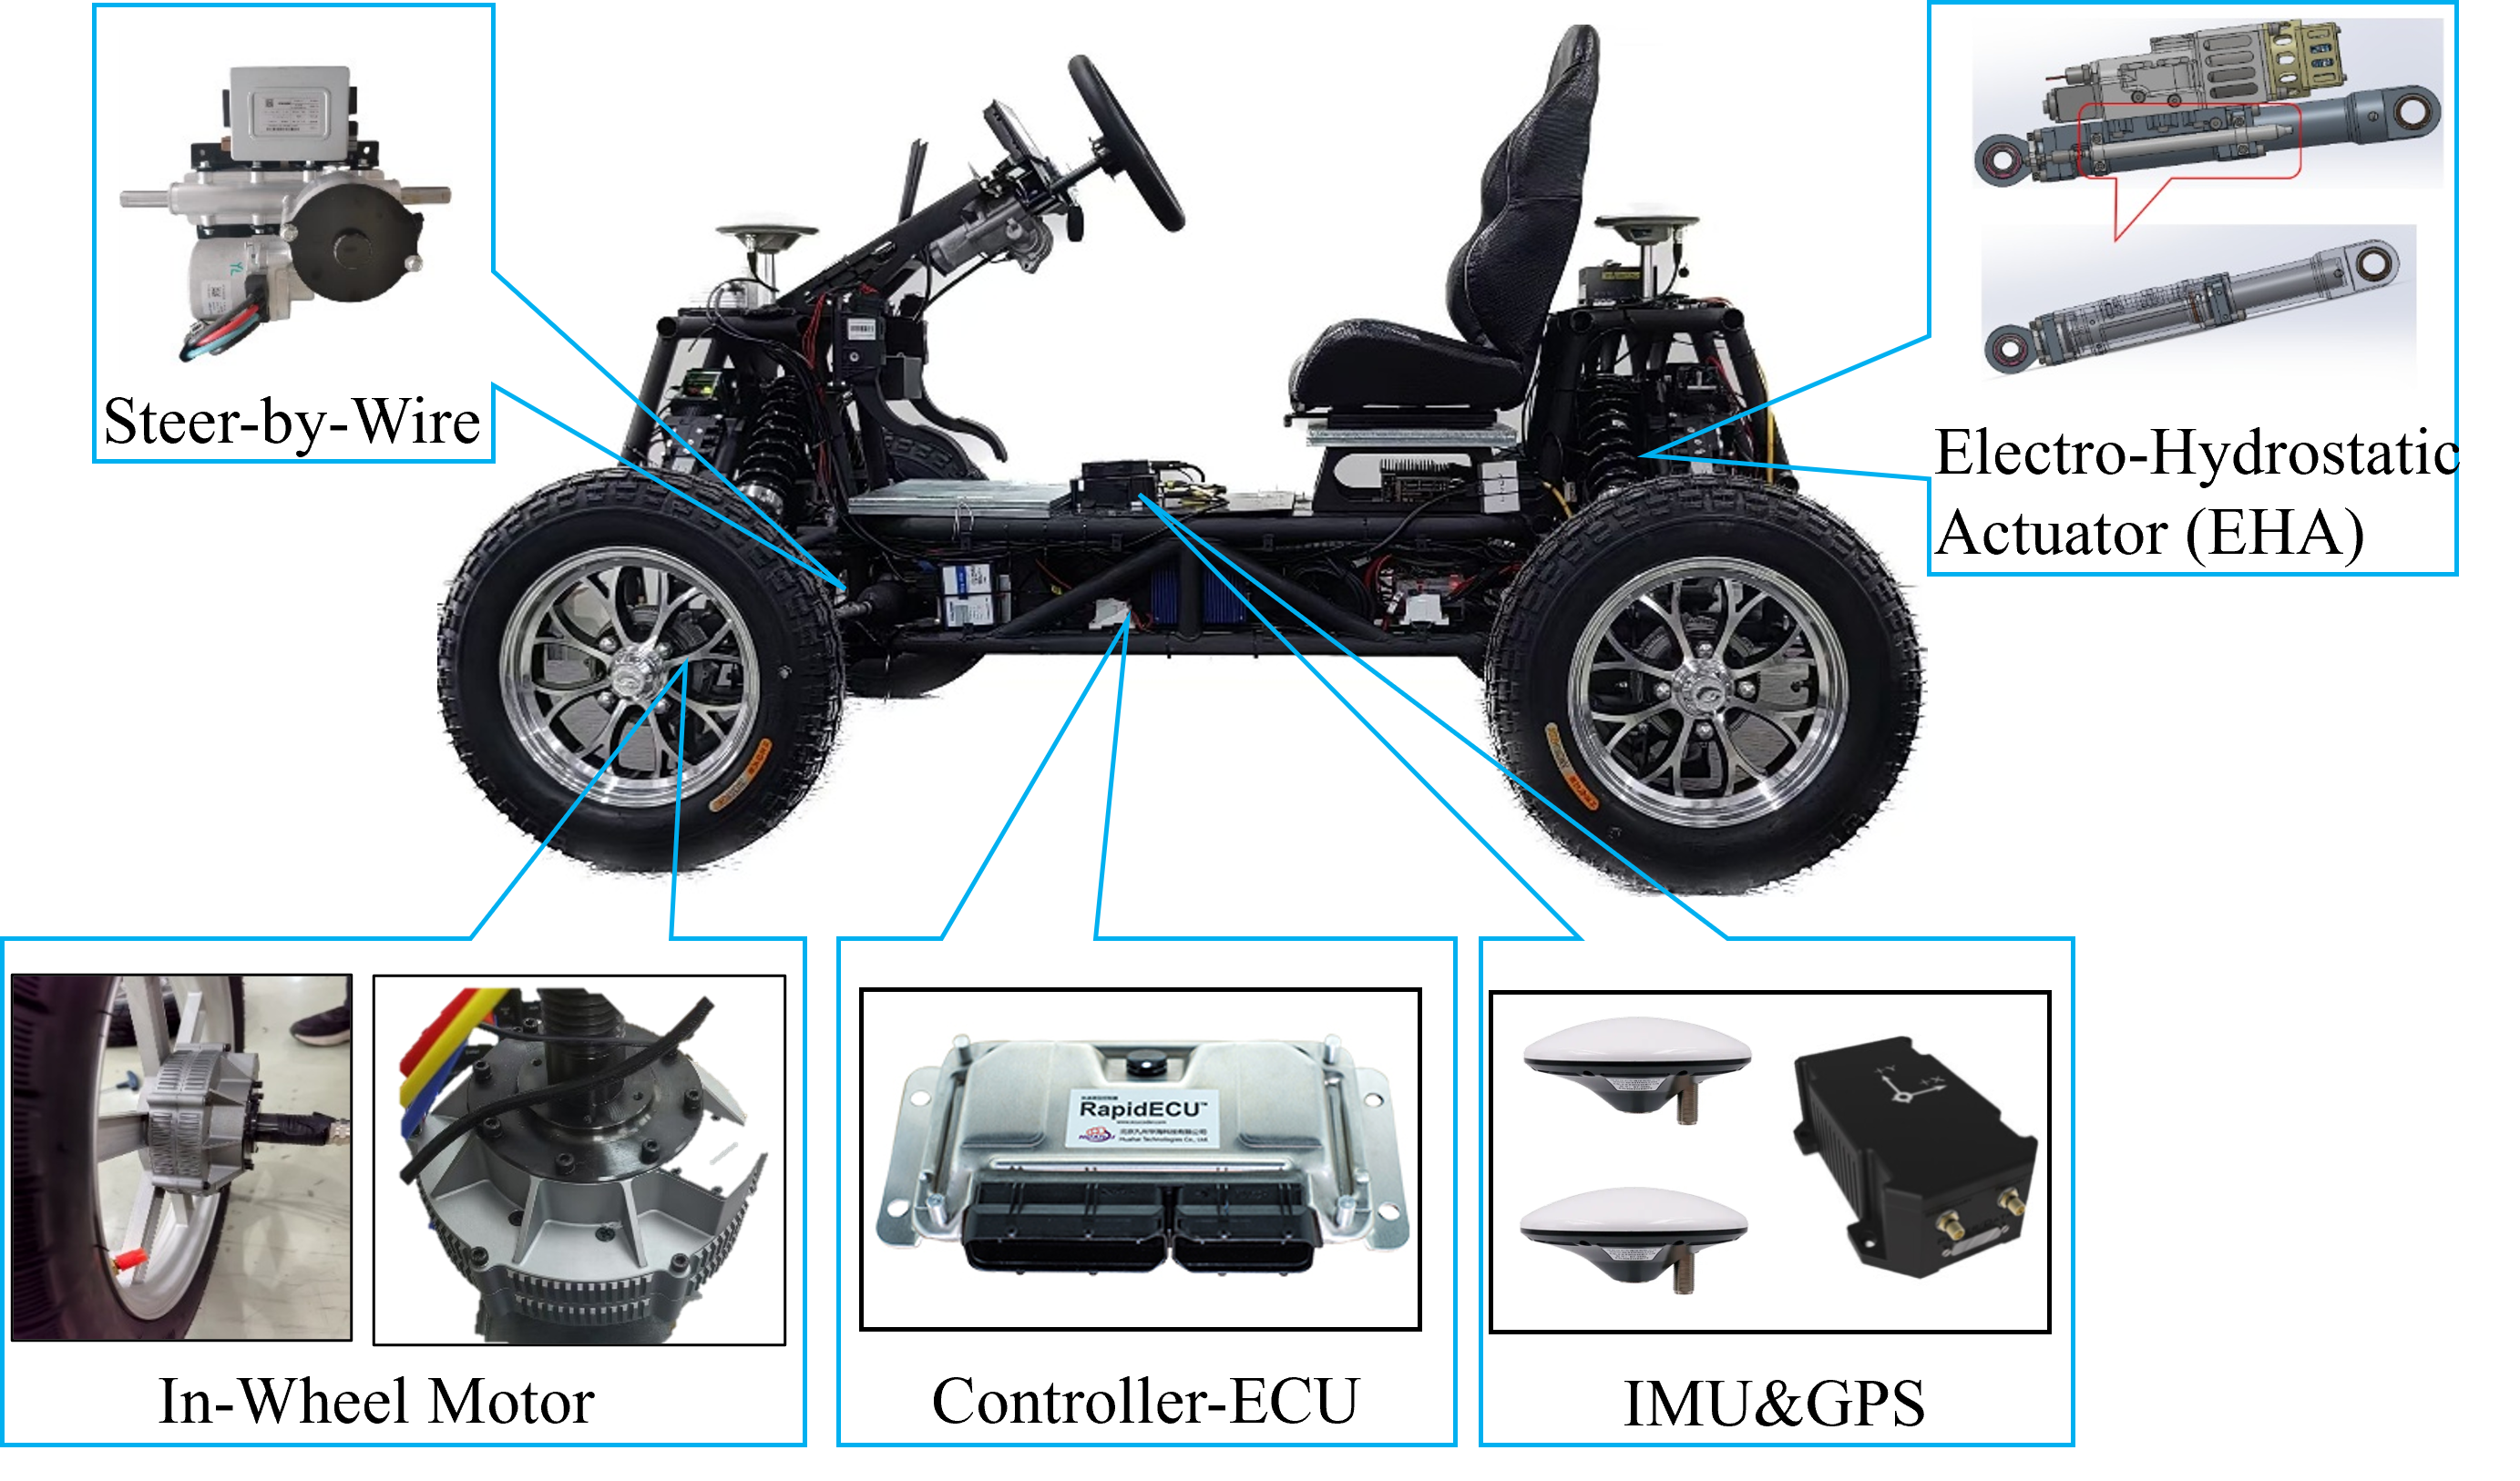
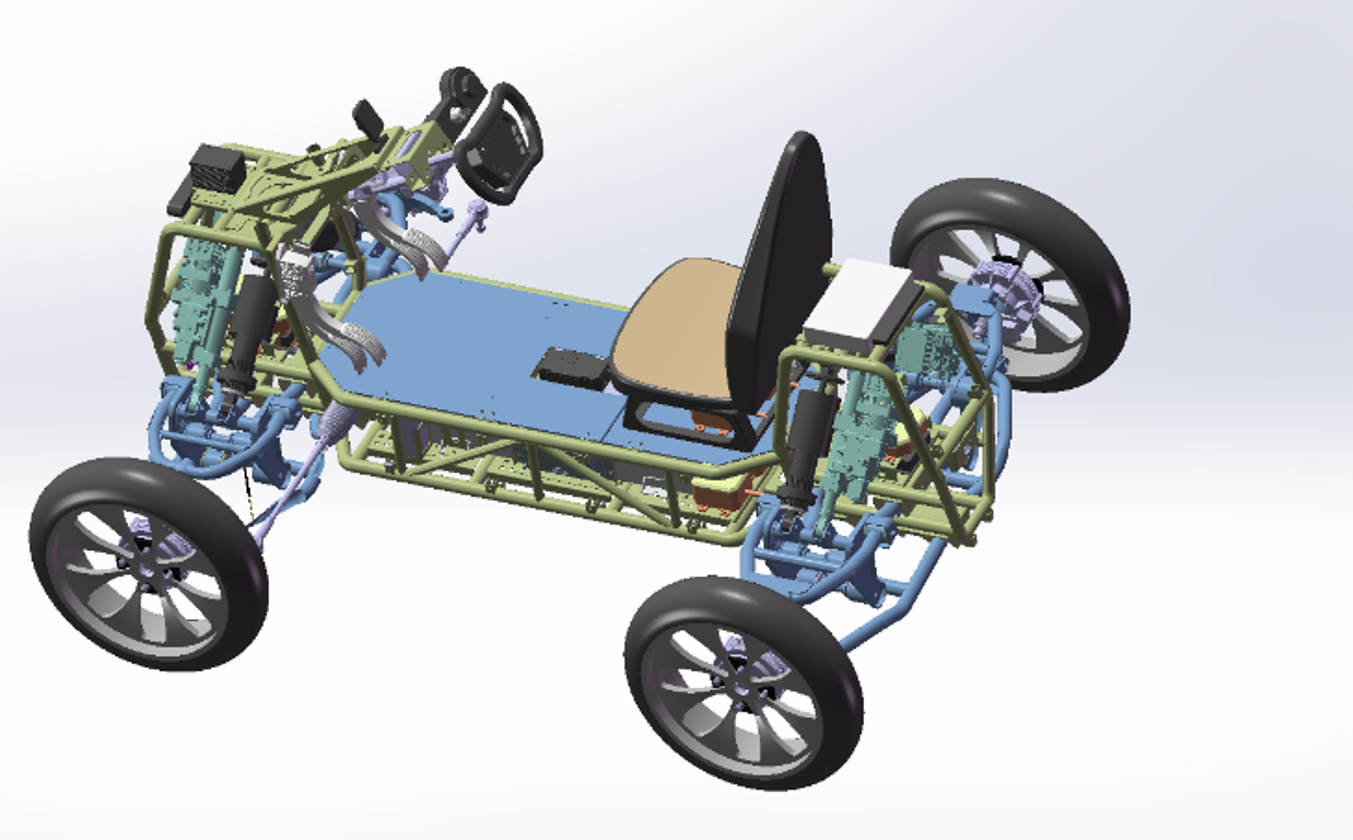
- Four-wheel-independent drive for flexible wheel-torque allocation.
- Steer-by-wire for accurate and programmable steering control.
- Active suspension for coordinated vertical and lateral dynamics control.
- Onboard sensing and real-time computation for experimental validation.
- Support for trajectory-tracking and vehicle-stability-control experiments.
- Electro-Hydraulic Brake (EHB) test for real vehicle platform (in progress…).
Experimental Demonstration
The following video presents the distributed-drive electric vehicle platform and its experimental capabilities.
If the embedded video cannot be played, watch it directly on YouTube →
Research Applications
The platform supports the experimental validation of distributed-drive control, vehicle stability analysis, coordinated trajectory tracking, chassis control, and autonomous-driving algorithms.